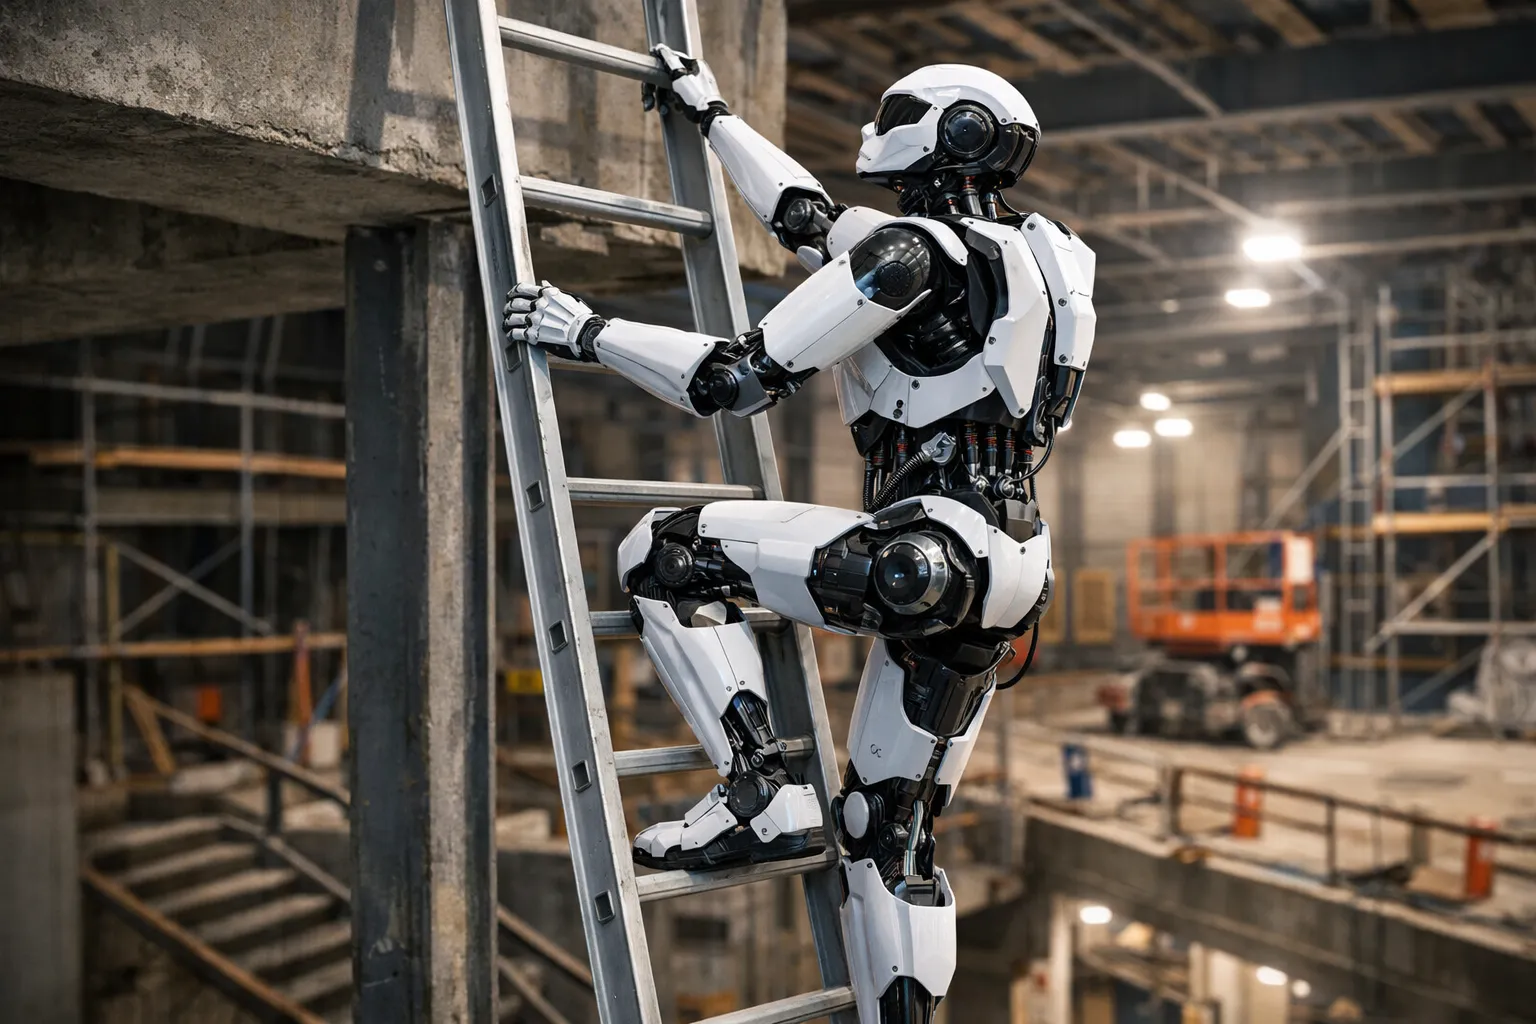
Researchers at ETH Zurich have developed an Artificial Intelligence control system that allows humanoid robots to navigate challenging physical environments, addressing key mobility challenges for bipedal robots on unstructured sites.
Tested on Unitree’s G1 humanoid robot, the system enabled the robot to climb vertical ladders, traverse unpredictable obstacles, crawl under low clearances, and recover autonomously from falls. Utilizing Reinforcement Learning and intelligent contact planning, the framework dynamically calculates ground contact points to maintain balance on narrow ladder rungs and uneven surfaces.
In trials across eight simulated obstacle courses, the system achieved a 92.5% success rate, significantly outperforming traditional control methods which scored 58.8% under the same conditions.
Designed to handle unexpected impacts without system resets, this resilient AI control framework represents a major advancement toward deploying humanoid robots in industrial, construction, and emergency response environments where navigating unstructured terrain is critical.
Reported by Mjengo Hub.
ETH Zurich Engineers AI Framework for Humanoid Robot Ladder Climbing